Describe the job your robot has to do. Effector Lab plans it as steps, tests every end effector it can simulate on every step, and recommends one tool, a tool change or a two-tool head, next to the best single off-the-shelf tool. This site replays recorded plans and runs, and can plan and test a new job live.
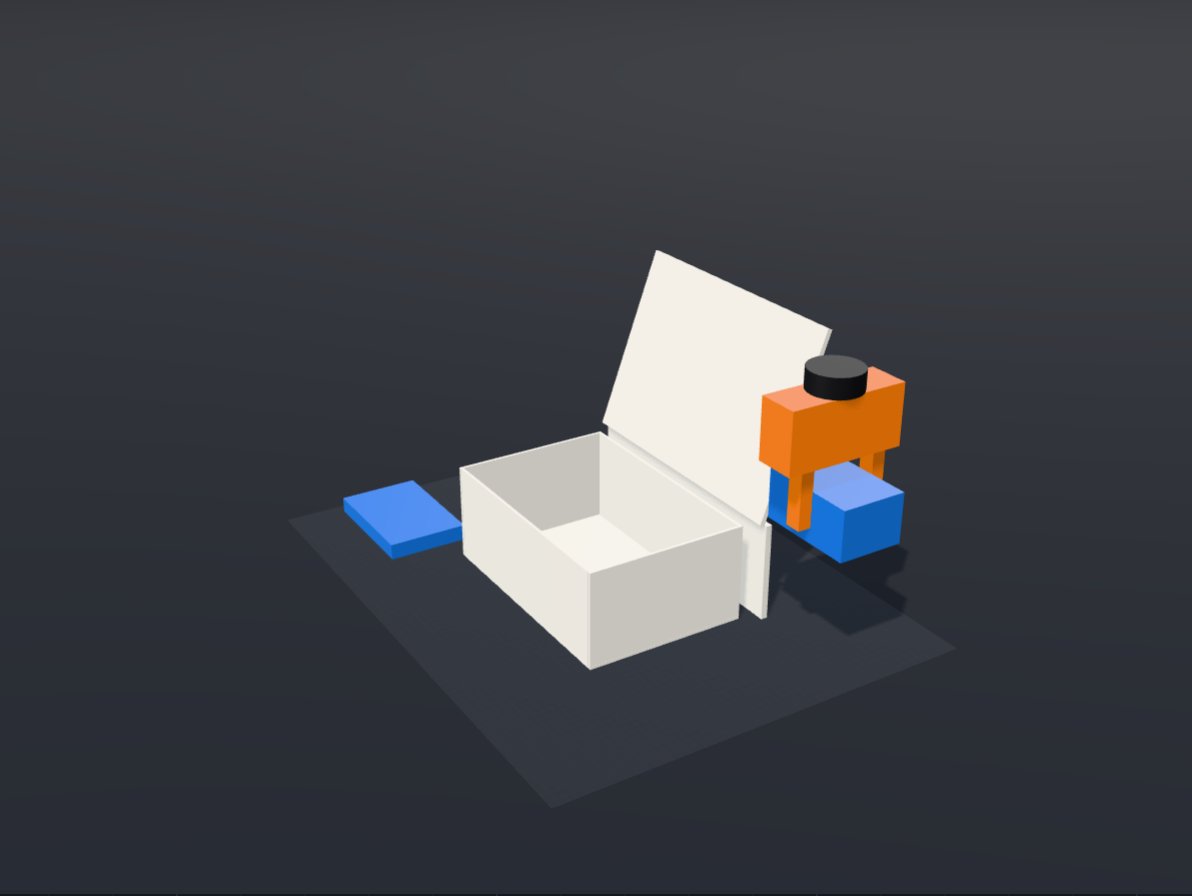
Industrial servo parallel gripper, 110 mm stroke. Hook the lid's lip and pull it open past vertical.
What it shows: the recommendation for the returns tote, a single industrial servo parallel gripper, 110 mm stroke, on its recorded run (nominal placement, seed 0). 1. Open the lid; 2. Pick the carton; 3. Pick the pack; 4. Close the lid. Done in 78.2 s.
Describe the job in plain words, and the planner turns it into objects and steps the simulator can run. Here you replay recorded plans and edit their steps, or plan a new job live with your own NVIDIA or Token Factory key, or a small free tier.
Every tool it can simulate tries every step it could do, in physics, on the same placements and seeds. Tools that cannot do a step are ruled out with a reason.
Single tools, tool changes and two-tool heads are combined from what passed, and the finalists run the whole task against the best single off-the-shelf tool.
Two pre-declared tests, frozen before their final runs, with the data in the repository.
Studio benchmark v1 (top-down wrist, 19 Oct): held-out conditions, three use cases
The Studio's pick74 of 96
Best single off-the-shelf tool0 of 96
Runs that finished the whole task, on conditions neither setup was chosen on, with the v1 setups. Returns tote: 32 of 32; Pipe coupling: 32 of 32; Equipment cabinet: 10 of 32.
v2 adds wrist tilt and honest tolerances; its benchmark is pending.
The language-model designer with feedback against equal-budget random search: 8.97 fewer on average (95% interval 3.5 to 14.2), exact permutation test p = 0.0011.
Simulated results. They rank tools under stated conditions; verify on hardware before you rely on them.
An open tool library
29 open, licence-checked end effectors with files, specs and a simulation status, alongside the families the Studio designs. These ones made it into a recommendation.